Radar and sensor integration
The radar on a working vessel uses its own network protocol. We decode it: the image stream, the tracked targets, the own-ship feed and the control interface. The radar then operates as a component of the system.
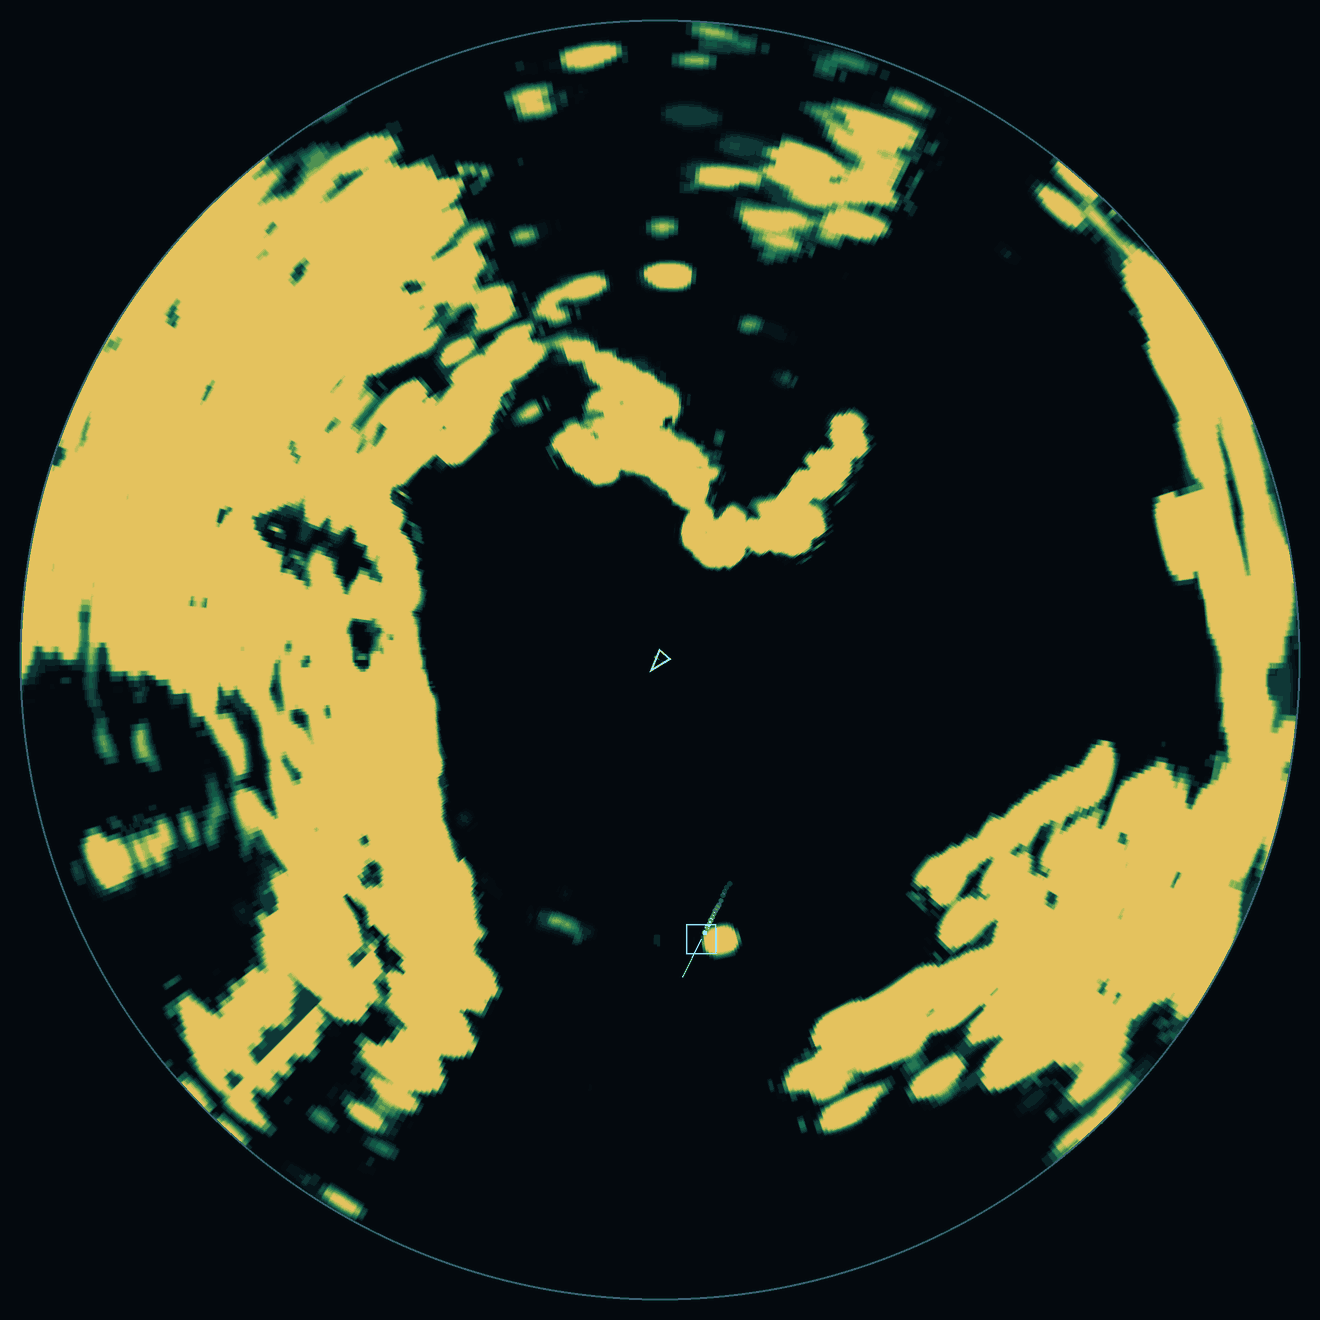 Decoded radar picture
| Image | The full radar image stream, decoded live. |
|---|---|
| Targets | ARPA tracked targets, once per antenna turn. |
| Own-ship feed | We supply the radar with a 10 Hz heading, position and course feed, built from the vessel’s own NMEA 2000 compass and GPS. |
| Control | Transmit, standby, range, gain, auto-acquire and guard zones. |
| Tracking | Our own tracker, fused with the camera detector, with a per-session shoreline guard. |
One thing we do not use
Raw ARPA velocity is unreliable for moored hulls, so the tracker does not use it. In a harbour, most radar returns come from vessels tied to a quay.