01 / Autonomy

Vessel autonomy stack

Six layers run on the vessel, from the mission down to the throttle. Each layer is a separate module with its own inputs and outputs.

The autonomy layer stack: six layers running on the vessel, with safety supervision shown separately as in development Mission waypoint · loiter · pattern Behaviour arbitration eight plugins · priority + safety override Motion policy speed limits from route geometry Guidance — ILOS path following cross-track error computed, logged, abort on deviation Vehicle control speed and yaw-rate reference tracking Helm bridge throttle and steering, speed loop closed Safety supervision IN DEVELOPMENT state machine and e-stop exist · no sensor inputs at sea open robotics base · per-hull profiles
Six layers run on the vessel. Safety supervision has a state machine and an e-stop path; its sensor-driven parts are not running at sea, so it is drawn outside the stack.
  • Missions Waypoint, loiter, racetrack and back-and-forth patterns.
  • Behaviours Eight plugins, arbitrated by priority with a safety override.
  • Path keeping Cross-track error computed and logged, with an abort on large deviation.
  • Speed Corner speed laws and end-of-route braking, from route geometry. Control is held at a commanded speed of 35 knots.
A dispatched route drawn as a dashed line through three waypoints, and the track the vessel actually ran drawn as a solid line beside it, running wide at the corner. The gap between the two is marked as cross-track error. cross-track error
Dispatched route Track run Guidance follows the dispatched line. The distance between that line and the track run is the cross-track error; it is computed and logged on every run, and the mission aborts if it exceeds the limit.
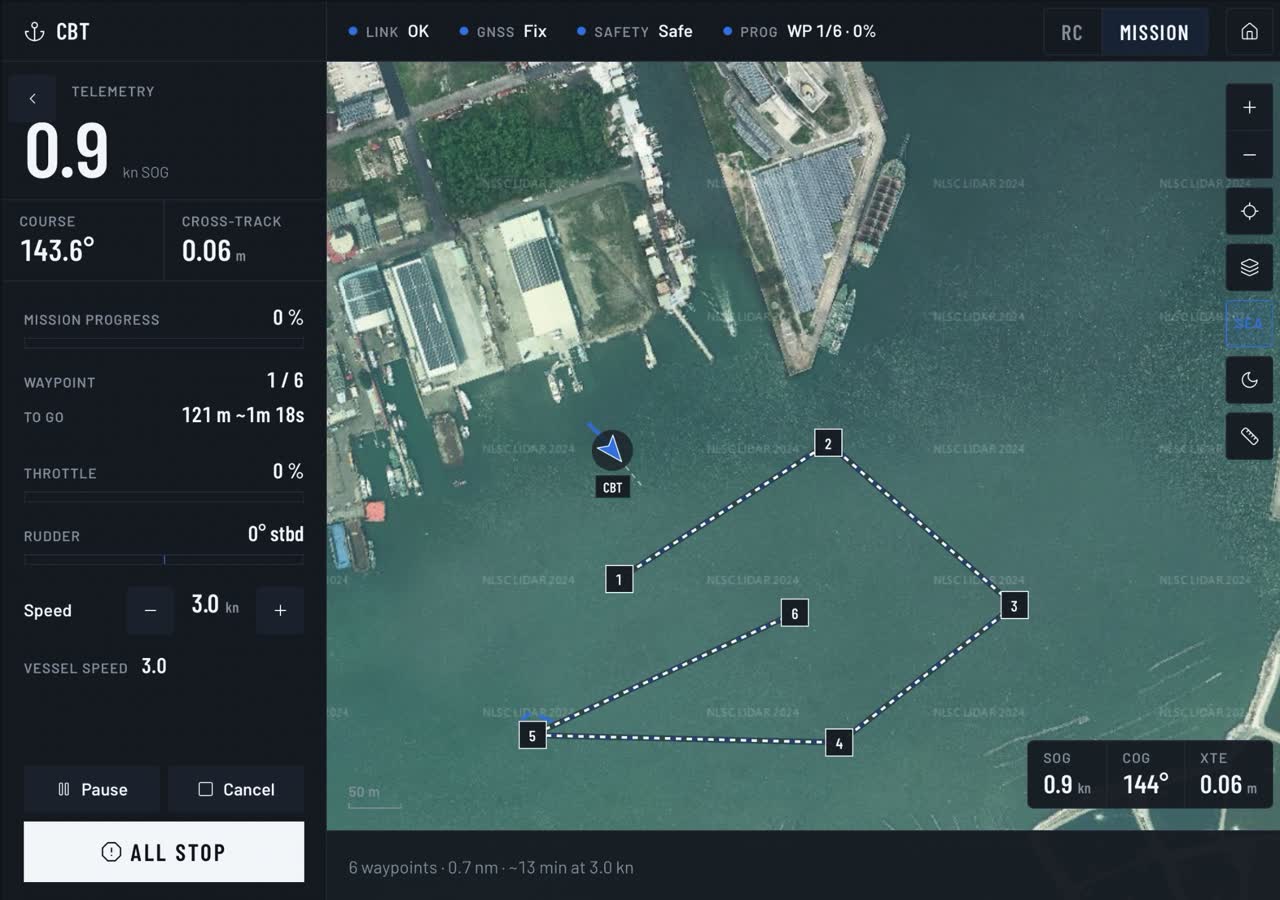
A tablet screen during a mission: a left column of readings — speed over ground, course, cross-track error, mission progress, waypoint, throttle and rudder — beside a chart showing six numbered waypoints joined by a dashed route, with the vessel marker near the first one. Guidance readout, as the tablet shows it
The quantity drawn above, as the vessel actually reports it: cross-track error reading 0.06 m, seconds after a six-waypoint mission was dispatched during a harbour sea trial in 2026. Throttle still reads zero — the vessel has not begun the first leg. Base map: NLSC, Ministry of the Interior
In development — not deployed at sea

A COLREGs collision-avoidance module is written and under simulator testing. It is off by default and has not been enabled on a vessel at sea.